Junjie Zhang | 张骏杰
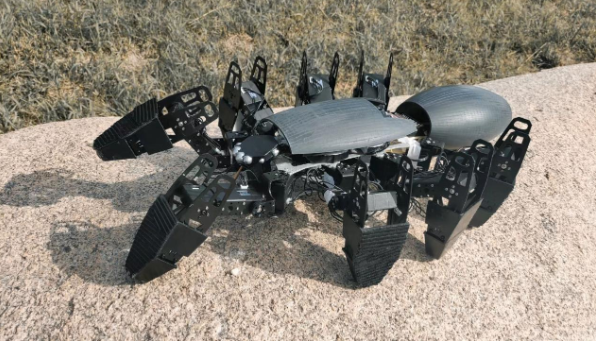
I am a master’s student at Chongqing University, expected to graduate in 2027. My current interests center on active vision for robotic manipulation, bio-inspired robotics, and UMI-style robot data collection.
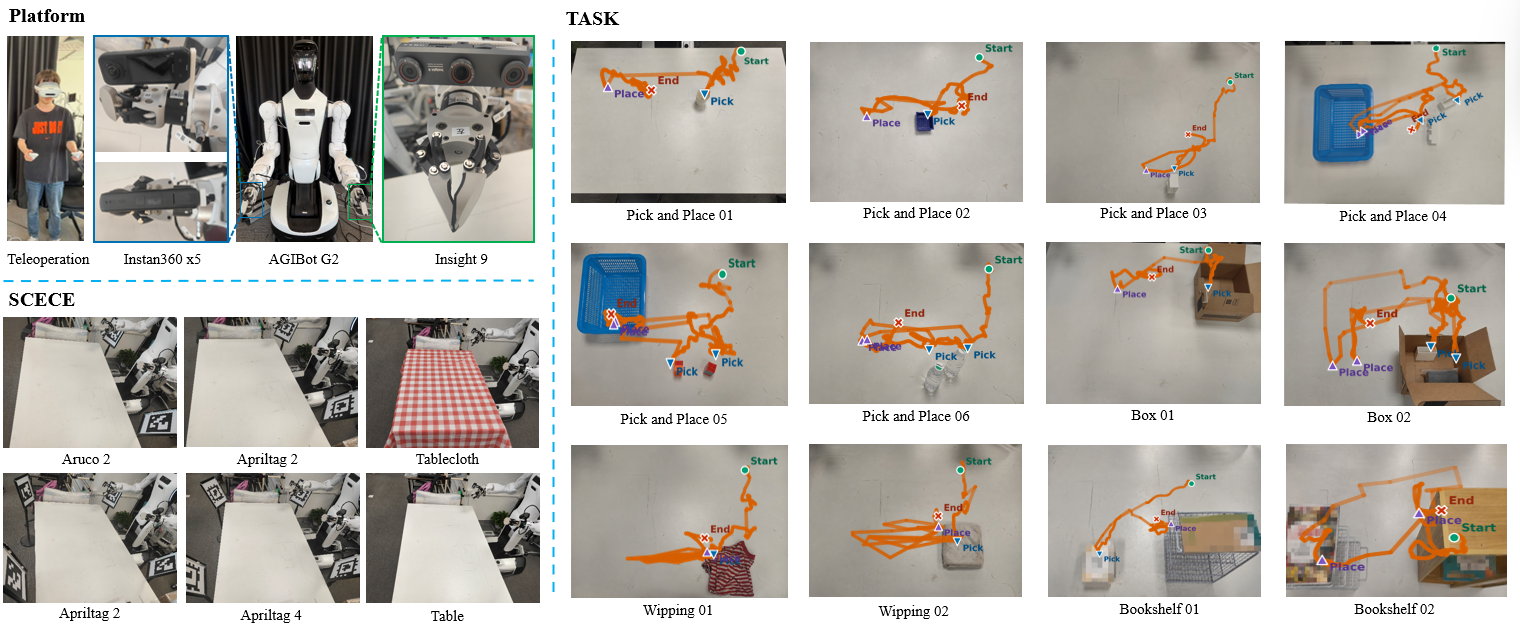
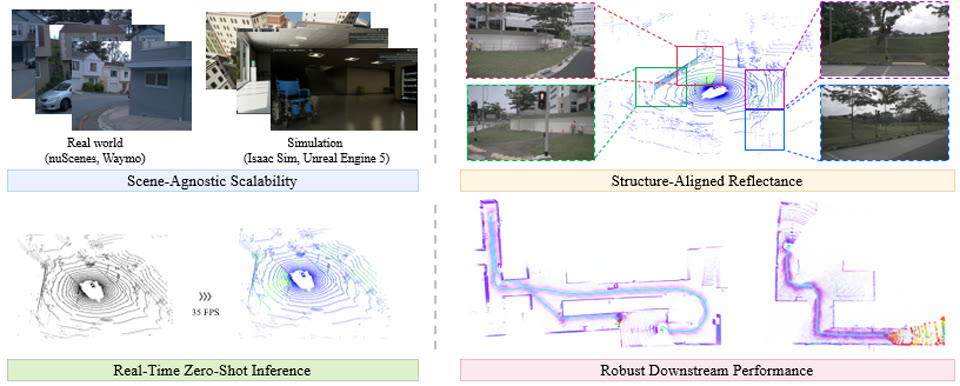
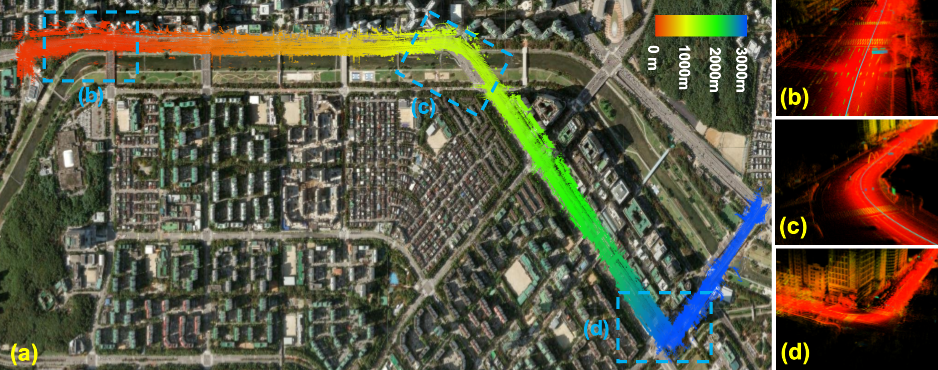
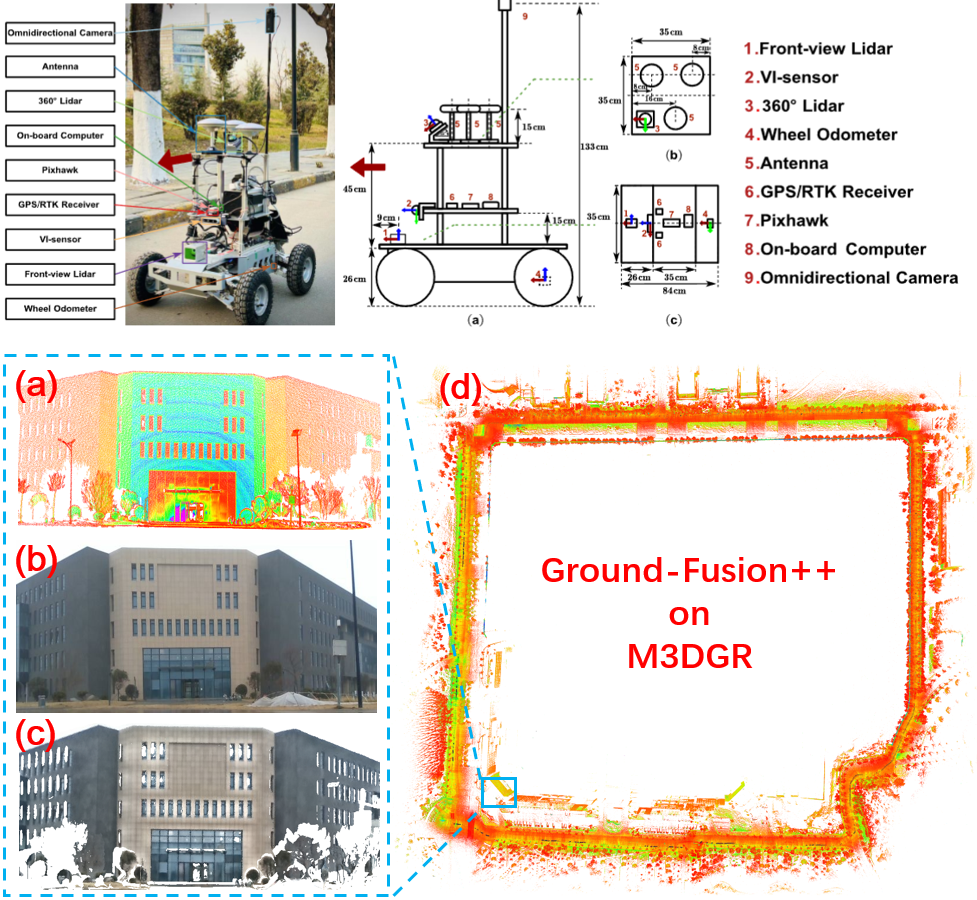
My work spans multi-sensor fusion SLAM, LiDAR intensity simulation, and end-effector localization, combining algorithm development with datasets and benchmarking. During internships at Shanghai AI Lab, PokeBot, and ENGINEAI, I worked on UMI (Universal Manipulation Interface) and whole-body UMI systems. My long-term goal is to contribute to the development of Physical AGI.
I am actively seeking robotics research and engineering roles, PhD opportunities, and like-minded co-founders to build a robotics venture.
Education
- 2024–2027 (expected) — Master’s in Mechanical Engineering, Chongqing University.
- 2020–2024 — Bachelor’s in Mechanical Design, Manufacturing and Automation, China University of Petroleum (Beijing).
Publications
-
-
-
-
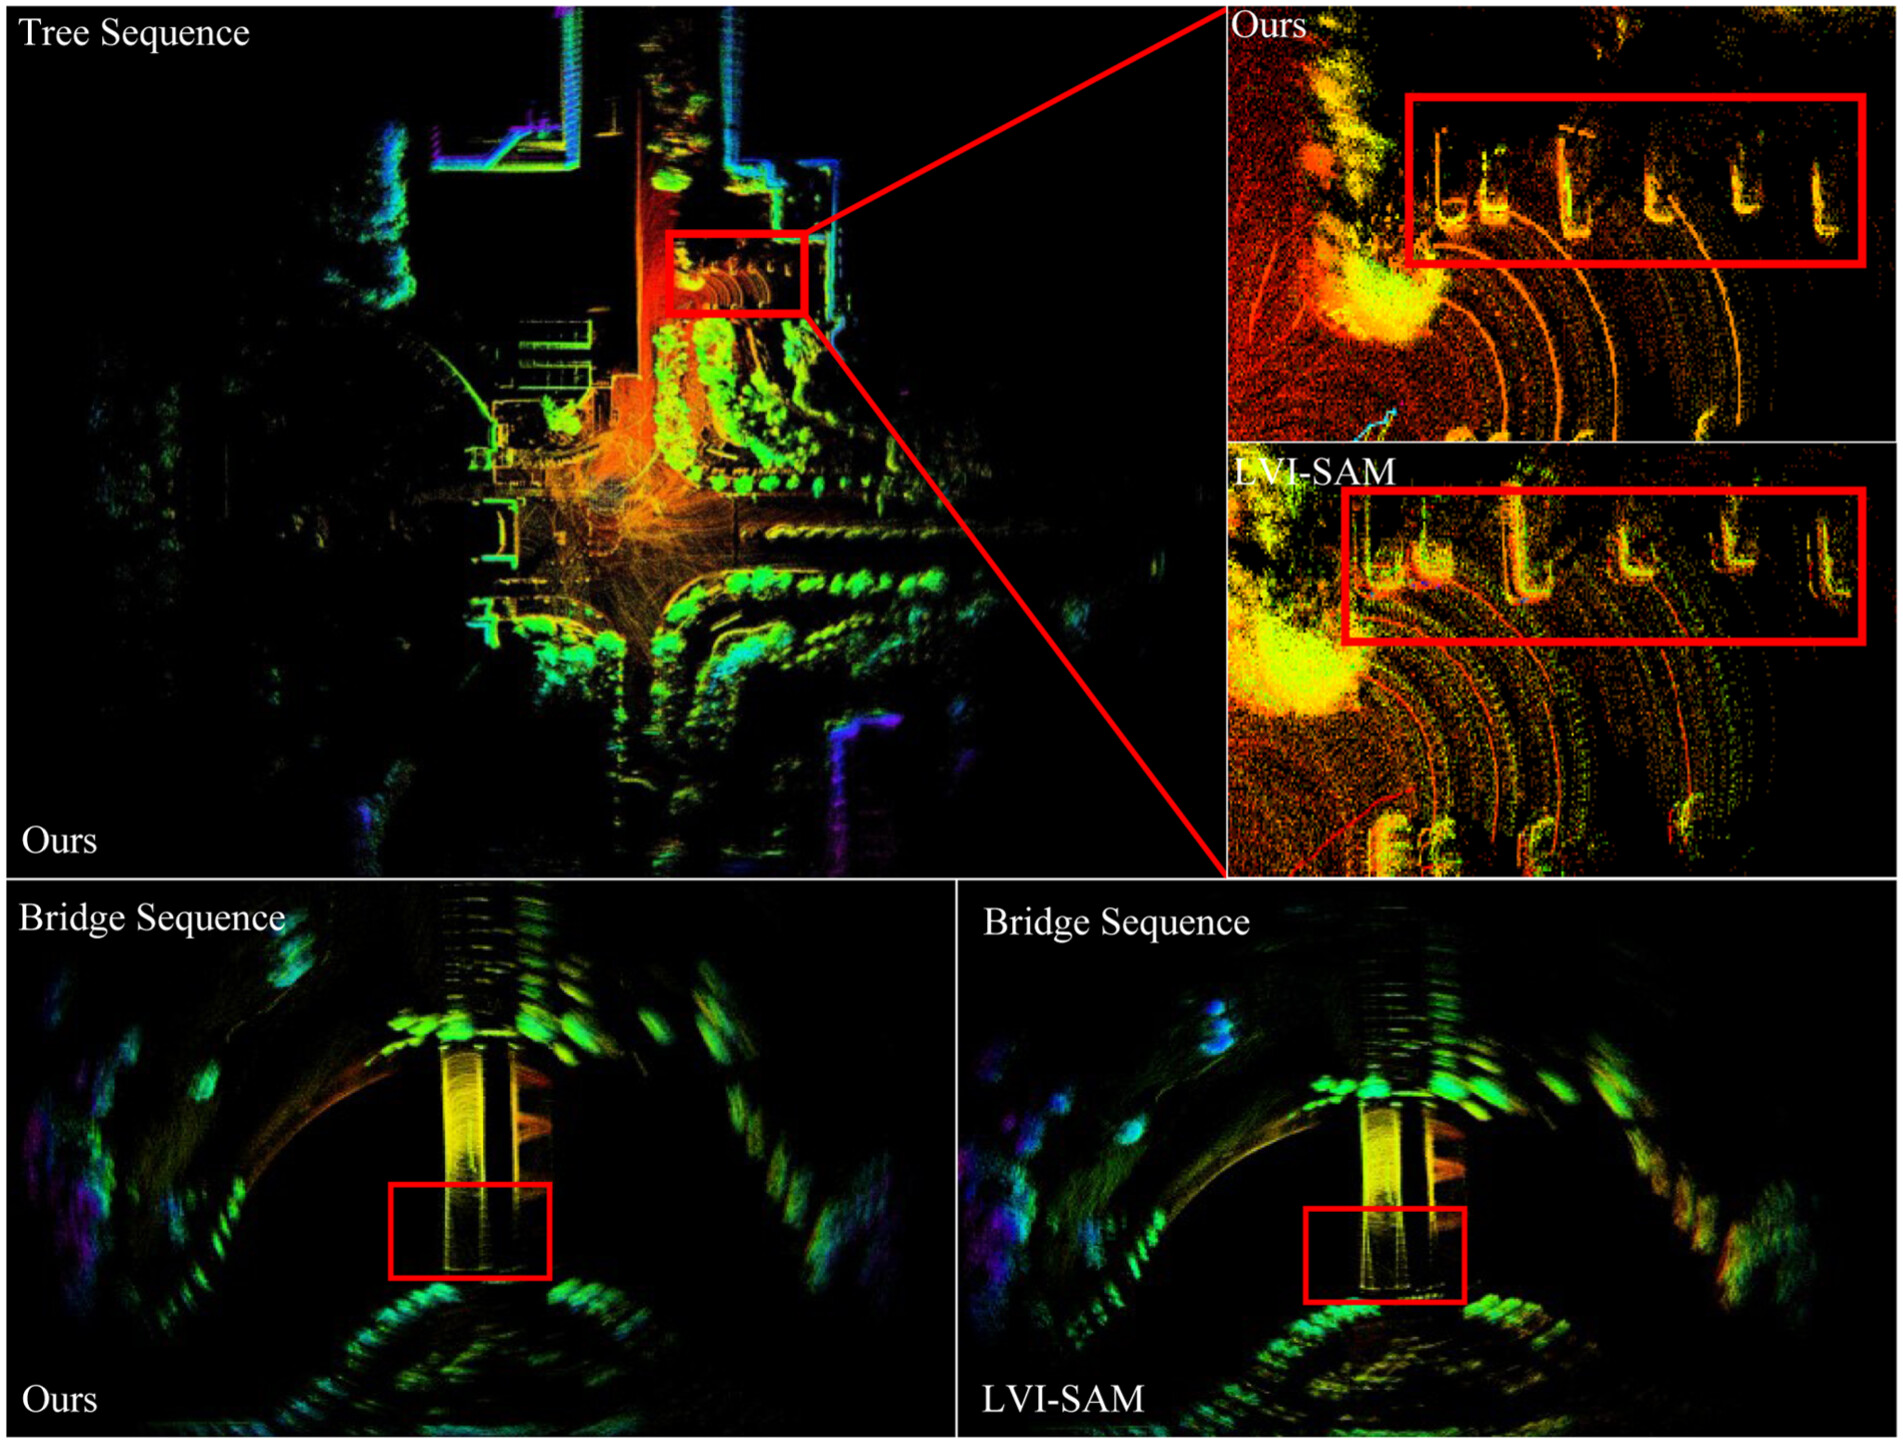
APGC-LVIW: LiDAR-visual-inertial-wheel SLAM with adaptive planar geometric constraints
Measurement and Control · 2025
-
-
Vision
I envision a future where robots help us build the world around us. I hope to find like-minded partners to turn that vision into reality.